Custom Servo Motor Magnets – Essential Design Considerations for Optimal Performance
2026-09-05
Custom servo motor magnets are the silent workhorses behind every high-performance motion system. Get the design wrong—wrong pole count, too wide an air gap, the wrong coating—and you'll see torque ripple, hot spots, and efficiency you didn't sign up for. Too often, engineers treat magnet specs as a datasheet item instead of a design lever. At DAWA, we've learned that small choices in magnet geometry and grade can make or break your servo's response. This post breaks down the essential considerations, from material selection to magnetization pattern, so you can avoid the usual prototyping headaches and build a servo that actually performs the way you designed it.
Getting the Air Gap Right Without Overbuilding
Achieving a proper air gap often gets reduced to a yes-or-no checkbox, but the real challenge is matching the isolation level to the actual risk you're defending against. A fully offline, manually mounted backup server is incredibly secure—yet it's also slow to restore from and easy to neglect during routine testing. On the other hand, a lightly obfuscated network share might technically be “separate,” but it won't stop a determined attacker who already owns your primary environment. The sweet spot usually lies in tiered isolation: critical recovery copies stay offline or in immutable cloud storage, while more frequently accessed replicas live in a tightly controlled, read-only network segment.
Overbuilding the gap shows up as rigid processes that quietly fall apart under pressure. When every restore requires a physical visit to a colocation cage or a five-person approval chain, teams start bypassing the system with informal copies on USB drives or personal cloud accounts—which are far less secure than a well-designed automated gap. A better approach is to define clear recovery time objectives first, then design the air gap backward from those numbers. If you need to be back online in four hours, a tape library in a different building may be pointless; instead, a write-once-read-many (WORM) object store with delayed deletion might give you the same protection without the operational drag.
Finally, remember that an air gap is only as good as its monitoring. A gap that no one tests or alerts on is just a gap in your imagination. Set up scheduled restore drills that actually pull data across the boundary, and instrument the isolation layer for anomalies—unexpected credential use, new network paths, or unusual deletion attempts. The goal isn't to build a fortress with a moat so wide that you drown in it; it's to create a verified, repeatable distance between your operational data and your last line of defense, one that holds under real-world pressure without strangling your team's ability to respond.
When Heat Soak Quietly Erodes Torque
Sitting in slow traffic after a hard pull, the intake manifold absorbs heat from the cylinder head until it becomes a secondary radiator. Once you finally get an open stretch, the engine pulls timing to protect itself because the incoming air is thinner and hotter. The result is a soft, almost lazy response where there should be a surge. This isn't a mechanical failure—it's heat soak quietly trimming torque at the margins.
The intercooler, often praised for its cooling capacity, becomes a heat reservoir once airflow stops. Heat radiates back into the charged air, and even a well-designed system can't undo the thermal mass effect in stop-and-go driving. Fuel temperature also rises, making the mixture less dense, which forces the ECU to compensate with shorter injection pulses or richer fuel trims. Each adjustment shaves a few newton-meters, and the cumulative loss is felt as a dulled throttle.
A larger intercooler helps only if it has the airflow to shed the stored heat, while phenolic spacers and ceramic-coated headers reduce the initial soak. Some tuners map around the phenomenon by adding timing back once intake temperatures stabilize, but this risks detonation on the street. The more honest approach is to accept that heat soak is an inherent part of forced induction, and a car that feels strong after a long idle is often the exception rather than the rule.
Why Off-the-Shelf Magnet Grades Fall Short
What many engineers discover after prototyping is that commercial magnet grades like N35 or N42 are optimized for cost, not for demanding duty cycles. Their maximum energy product looks fine on a datasheet, but at 80°C the actual flux drops faster than the linear demagnetization curves suggest. In high-precision actuators or sensors, that drift means recalibration or outright failure.
The coating and dimensional tolerances on stock magnets also create hidden problems. Off-the-shelf parts often use thin nickel-copper-nickel plating that chips under mechanical load, exposing the NdFeB core to corrosion. Meanwhile, the ±0.1 mm or looser thickness variation forces designers to add air gap, which directly sacrifices the field strength they selected the grade for in the first place.
For applications that need repeatable pull force or stable reluctance across a temperature range, a custom grade with higher coercivity—like an H or SH variant—may be unavoidable. Selecting only by N-number ignores the knee point of the BH curve, and that oversight is exactly where off-the-shelf magnets fall short.
Balancing Rare Earth Costs Against Real Performance Gains
Rare earth elements like neodymium and dysprosium command steep prices and supply-chain risks, yet they deliver magnetic performance that ferrite or induction alternatives often can't match at the same size. The real question isn't whether rare earths are expensive—it's whether the extra cost translates into a measurable advantage for the specific application. In high-torque-density motors for robotics or aerospace, a 20% improvement in flux density might justify a 40% material premium. In a stationary industrial pump that runs at constant speed, that same premium likely buys nothing but a thinner margin.
A useful frame is to look at total lifecycle cost rather than just material invoice. Rare earth magnets may reduce copper losses, shrink cooling requirements, or allow a smaller housing, which can offset their upfront cost through energy savings and reliability gains. But those offsets only materialize under certain duty cycles. Intermittent or low-load applications rarely recoup the premium, while continuous high-efficiency systems often do—sometimes within the first few years.
Supply volatility adds another layer. Prices for dysprosium and terbium have swung dramatically after export controls or geopolitical shifts, making long-term budgeting difficult. Some engineering teams now hedge by designing rotors that can accept either sintered rare earth magnets or lower-cost ferrite with a performance derate. That modular approach preserves sourcing flexibility while keeping the door open to future rare earth price drops—or further spikes.
Coatings That Survive More Than Salt Spray
Salt spray cabinets have long been the default benchmark for corrosion resistance, but a 1,000-hour rating often says little about how a coating will hold up on a bridge in Miami or a chemical plant in Houston. Real-world failure usually comes from a combination of UV degradation, thermal cycling, and wet-dry cycles that a constant salt fog never replicates. That's why formulators are moving beyond a single pass/fail test and looking at how a coating behaves when it's punished by multiple stressors at once.
The latest high-performance systems earn their keep by combining sacrificial pigments, barrier resins, and adhesion promoters that work differently depending on the exposure scenario. A zinc-rich primer may protect steel at a scribe, but it won't stop filiform corrosion if the topcoat loses gloss and cracks under sunlight. Modern approaches layer an epoxy intermediate with a urethane or polysiloxane finish, and some add encapsulated corrosion inhibitors that activate only when moisture reaches the metal—so the coating responds to damage instead of just sitting there.
To really judge a coating's lifespan, engineers are increasingly relying on cyclic corrosion tests like GMW 14872 or ISO 20340, which alternate salt spray with drying, humidity, and UV. Data from those protocols, paired with electrochemical impedance spectroscopy, reveals how quickly a coating's resistance drops over time—not just whether it blisters at 500 hours. That shift toward performance-based evaluation is what separates a coating that survives a test chamber from one that survives a decade outdoors.
How Tight Tolerances Keep Servo Loops Honest
In motion control, the gap between commanded and actual position often grows from the smallest mechanical slack. Tight tolerances on couplings, bearings, and mounting surfaces remove the hidden deadband that servo loops must otherwise fight against. When every component fits within a few microns, the loop sees the true plant response instead of a blurred average, so its corrections land precisely where the math says they should.
Backlash and compliance act like noisy feedback that no amount of loop gain can fully erase. A shaft that shifts a thousandth of an inch under load forces the servo to hunt, overshoot, and then settle slowly. By holding bore concentricity and keyway fit to a fraction of that, the mechanical path becomes predictable and repeatable. The loop no longer wastes bandwidth compensating for slop; it simply tracks the profile, and errors stay honest.
Temperature drift and wear also enter through loose fits, slowly corrupting the loop's tuning assumptions. Tight tolerances keep those drift sources small enough to ignore over years of service. The servo then behaves the same on Monday morning and Friday afternoon, tuned once and left alone. That is the bargain: precision machining buys a control loop that tells the truth, cycle after cycle.
FAQ
Neodymium iron boron offers the highest energy density and is usually the first choice, while samarium cobalt gets selected when the motor will run hot or encounter corrosive conditions. The final decision often hinges on the balance between cost, temperature limits, and required flux density.
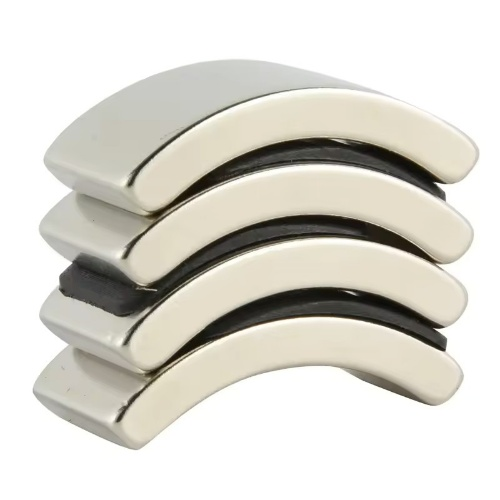
It depends on the rotor architecture. Arc or bread-loaf segments wrap neatly around the shaft and help produce a sinusoidal back-EMF, while rectangular blocks can work if the rotor hub is milled with flat seats. Air gap consistency and ease of assembly often tip the scale.
Servo motors can cycle between cold idle and high-load operation quickly. If the magnet's working point is too close to its demagnetization knee at peak temperature, you risk irreversible flux loss. A design review should confirm the magnet grade survives the hottest expected condition under load.
Tight tolerances on the inner radius and thickness are critical for uniform air gap and rotor balance, but over-specifying every dimension drives up cost. Usually the mating surfaces get tight control while non-critical faces can relax to standard commercial tolerances.
Yes. Neodymium magnets need protection against corrosion, especially in humid environments. Epoxy or nickel-copper-nickel coatings are common, but in a sealed motor cavity a thin epoxy layer might be enough. If the motor may see oil mist or coolant, the coating needs to withstand that exposure.
The orientation pattern influences torque ripple and back-EMF waveform. Radial or parallel magnetization may be used depending on pole count and winding layout. For low cogging, some designs use skewed magnetization or segmented poles, which requires careful fixturing during magnetizing.
A small batch lets you verify the assembly process, measure actual flux distribution, and test thermal stability before committing to production quantities. Issues like glue voids, incorrect pole alignment, or coating damage often show up only when you build a real rotor.
Usually the material grade and the amount of waste generated by machining complex shapes. Larger blanks, unusual radii, or very tight tolerances can raise scrap rates. Simplifying the shape or adapting standard arc sizes can reduce cost without sacrificing much performance.
Conclusion
Custom servo motor magnets rarely reward a one-size-fits-all approach. The air gap is a good place to start: closing it down improves torque constant, but only up to the point where rotor-stator deflection, thermal expansion, or assembly runout starts creating rubs. Overbuilding with thicker magnets or tighter gaps than the application actually needs adds inertia and cost without a proportional gain. Then heat enters the picture. A grade that tests beautifully at 20°C can lose a meaningful chunk of flux by the time windings settle at 140°C, and repeated thermal cycling can quietly erode what looked like a safe margin against demagnetization. That is why off-the-shelf N42 or N48 stock often falls short in continuous-duty servos; high intrinsic coercivity and a carefully chosen operating point on the BH curve matter more than room-temperature remanence alone.
Cost conversations tend to focus on dollars per kilogram of rare earth, but that hides the real trade-off. A slightly lower-energy magnet with better high-temperature stability can deliver more usable torque per dollar than a premium grade that requires active cooling or a larger motor frame. Segmentation helps here too: breaking the magnet ring into smaller blocks reduces eddy-current heating, which protects both the magnet and the loop gain. Coatings deserve equal scrutiny. Salt spray is the baseline test, but servomotors see thermal shock, gear oil mist, and condensation; a coating that passes 48 hours in a cabinet may still flake after a few thousand hot-cold cycles. Finally, tolerances are not just a drawing exercise. Variation in magnet thickness, chamfer angle, or parallelism shows up as cogging ripple, unbalanced back EMF, or rotor imbalance, and the servo loop ends up fighting those errors at every update. When the magnets are consistent, the loop can stay honest.
Contact Us
Contact Person: Kelvin Lo
Email: [email protected]
Tel/WhatsApp: 0769-88561131
Website: https://dawamagnetic.com/